#include <body3dcontroller.h>
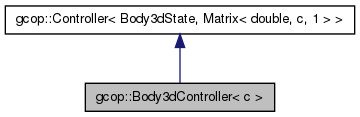
Inheritance diagram for gcop::Body3dController< c >:
Collaboration diagram for gcop::Body3dController< c >:
Public Types | |
| typedef Matrix< double, c, 1 > | Vectorcd |
Public Member Functions | |
| Body3dController (const Body3d< c > &sys, Body3dState *xd=0, Vector6d *ad=0) | |
| virtual bool | Set (Vectorcd &u, double t, const Body3dState &x) |
| virtual | ~Body3dController () |
Public Attributes | |
| const Body3d< c > & | sys |
| system | |
| Body3dState * | xd |
| desired state (origin by default) | |
| Vector6d * | ad |
| desired acceleration (zero by default) | |
| Vector6d | Kp |
| proportional terms (ones by default) | |
| Vector6d | Kd |
| derivative terms (twos by default) | |
Detailed Description
template<int c = 6>
class gcop::Body3dController< c >
Rigid body PD controller using errors on 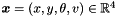
Author: Marin Kobilarov, 2007
Member Typedef Documentation
template<int c = 6>
| typedef Matrix<double, c, 1> gcop::Body3dController< c >::Vectorcd |
Constructor & Destructor Documentation
template<int c>
| gcop::Body3dController< c >::Body3dController | ( | const Body3d< c > & | sys, |
| Body3dState * | xd = 0, |
||
| Vector6d * | ad = 0 |
||
| ) |
BODY3D PD controller
- Parameters:
-
sys multi-body system xd desired state (optional, set to origin by default) ad desired acceleration (optional, set to zero by default)
References gcop::Body3dController< c >::Kd, and gcop::Body3dController< c >::Kp.
template<int c>
| gcop::Body3dController< c >::~Body3dController | ( | ) | [virtual] |
Member Function Documentation
template<int c = 6>
| virtual bool gcop::Body3dController< c >::Set | ( | Vectorcd & | u, |
| double | t, | ||
| const Body3dState & | x | ||
| ) | [virtual] |
Feedback controller of the form u = k(t, x)
- Parameters:
-
u controls t time x state
- Returns:
- true if arguments are valid, false if e.g. x is infeasible
Implements gcop::Controller< Body3dState, Matrix< double, c, 1 > >.
Member Data Documentation
template<int c = 6>
| Vector6d* gcop::Body3dController< c >::ad |
desired acceleration (zero by default)
template<int c = 6>
| Vector6d gcop::Body3dController< c >::Kd |
derivative terms (twos by default)
Referenced by gcop::Body3dController< c >::Body3dController().
template<int c = 6>
| Vector6d gcop::Body3dController< c >::Kp |
proportional terms (ones by default)
Referenced by gcop::Body3dController< c >::Body3dController().
template<int c = 6>
| const Body3d<c>& gcop::Body3dController< c >::sys |
system
template<int c = 6>
| Body3dState* gcop::Body3dController< c >::xd |
desired state (origin by default)
The documentation for this class was generated from the following file:
- lib/algos/body3dcontroller.h